About me
Automation and Controls Engineer specializing in industrial automation, PLC/SCADA systems, real-time manufacturing data, and robotics control. Currently at Trusscore, I develop and deploy production-critical automation solutions in a high-volume PVC extrusion environment, integrating PLCs, vision systems, databases, and enterprise software into unified control and monitoring systems.
I design end-to-end industrial solutions using Ignition, Studio 5000, FactoryTalk, SQL, and Python, including SCADA/HMI applications and real-time production monitoring platforms. I have built multi-threaded industrial software integrating Keyence barcode systems with custom OCR pipelines for real-time part validation across multiple extrusion lines. I also support PLC integration, electrical troubleshooting, and OPC UA-based communication between machines and enterprise systems.
My work extends into manufacturing intelligence, including inline quality systems for dimensional inspection, defect detection, and color/gloss analysis. I evaluate and deploy industrial sensing technologies (Micro-Epsilon, Cognex, LMI, X-Rite) and build SQL pipelines with Power BI/Power Apps dashboards for traceability and operational analytics.
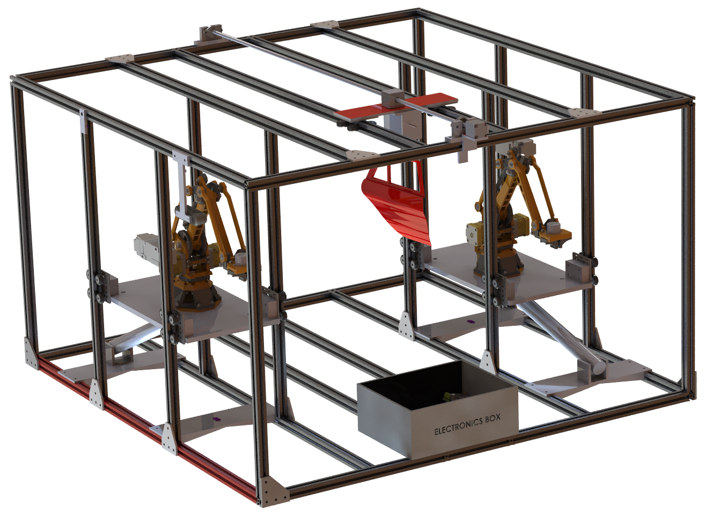
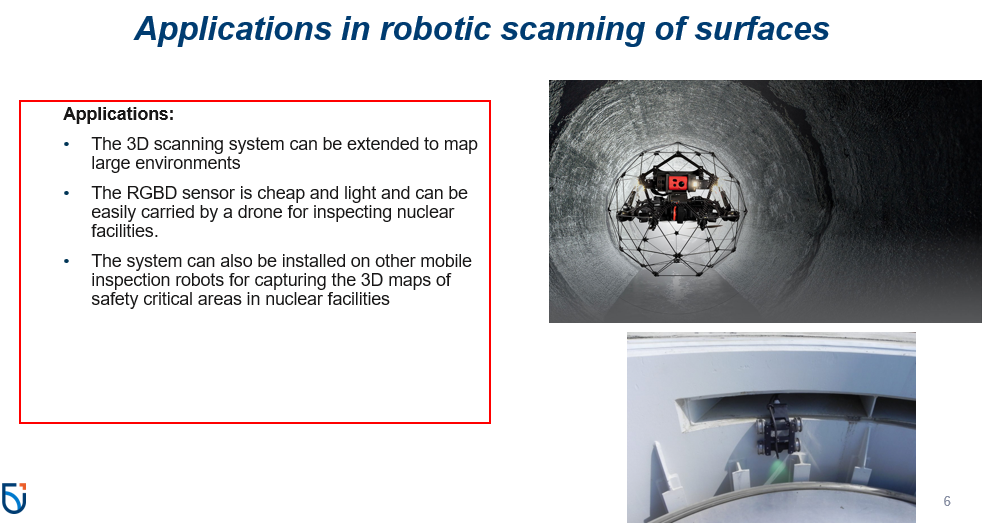
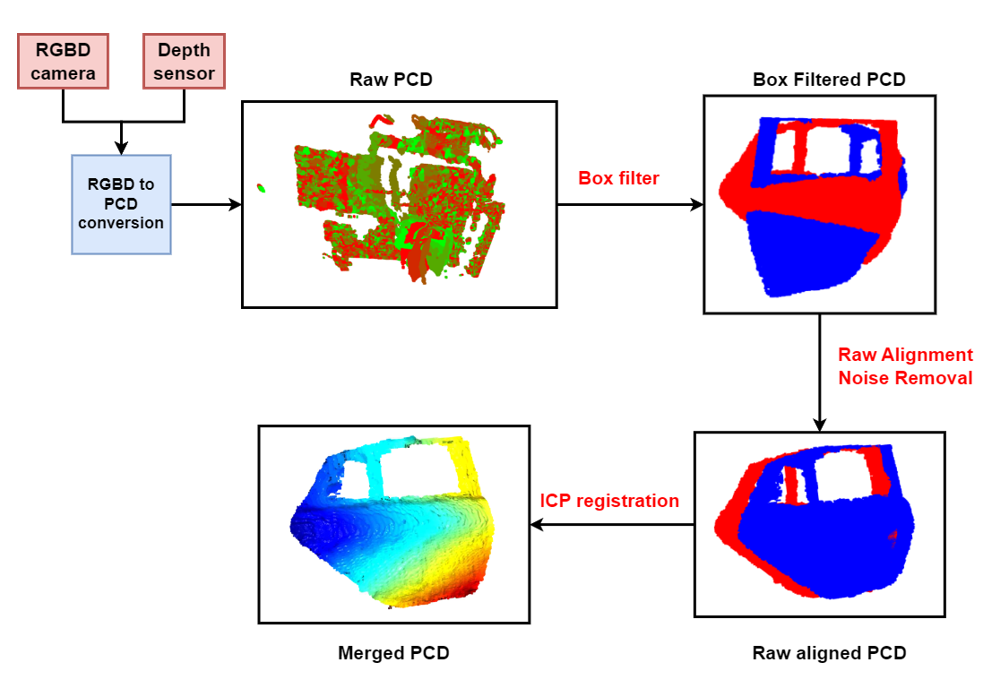
Previously, during my MSc at Ontario Tech University, I focused on robotics and automation, developing an RGB-D 3D scanning system (95% accuracy), a hybrid trajectory optimization method (51% energy reduction, 33% cycle time improvement), and ROS-based robotic control frameworks with web HMIs. I also developed automated trajectory planning for industrial spray-painting systems validated across FANUC, KUKA, and ABB robots.
Expertise
-
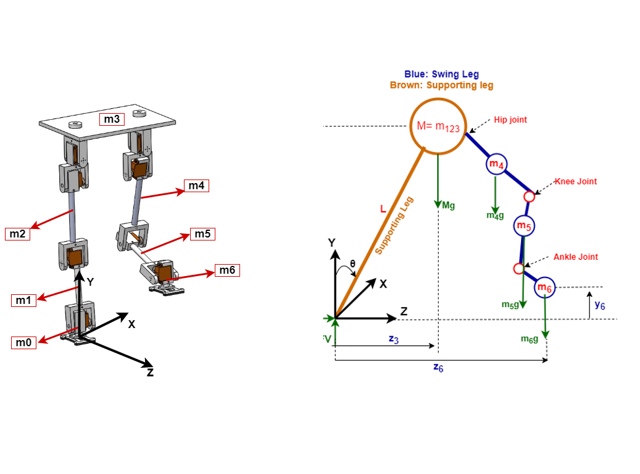
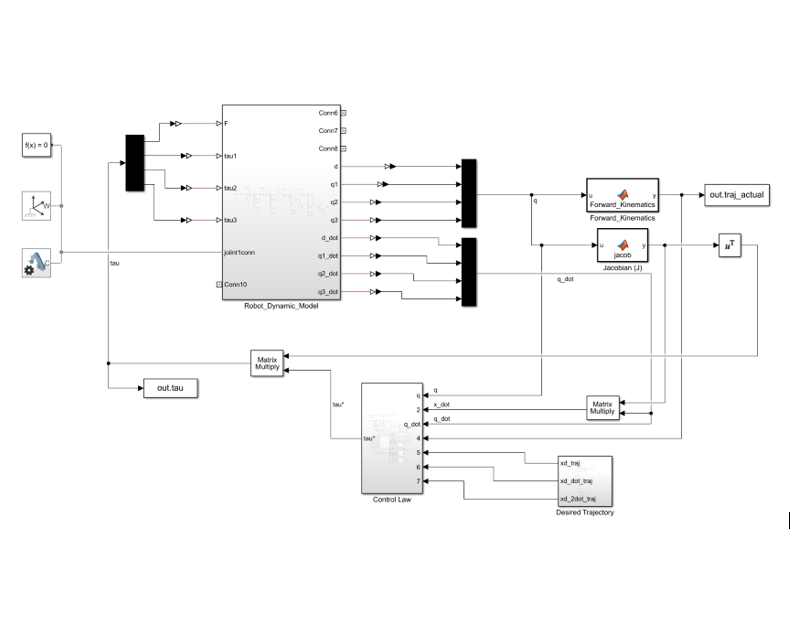
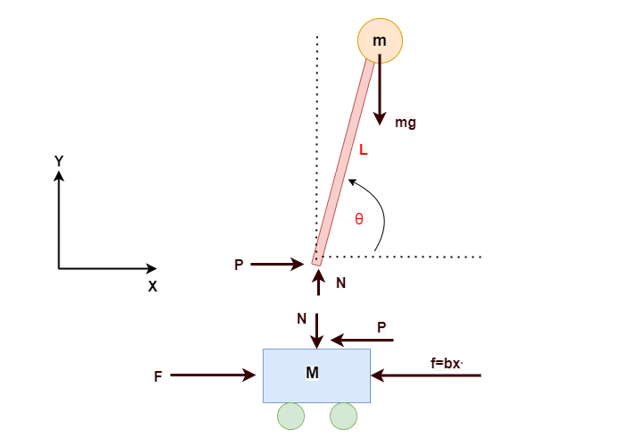
Electromechanical Modelling
Model system dynamics for deeper process understanding.
-
PLC and SCADA
Studio 5000, Ignition, FactoryTalk.
-
ROS
Deep understanding of ROS1 and ROS2 topics, services, actions, launch, rviz, gazebo, nav2 etc.
-
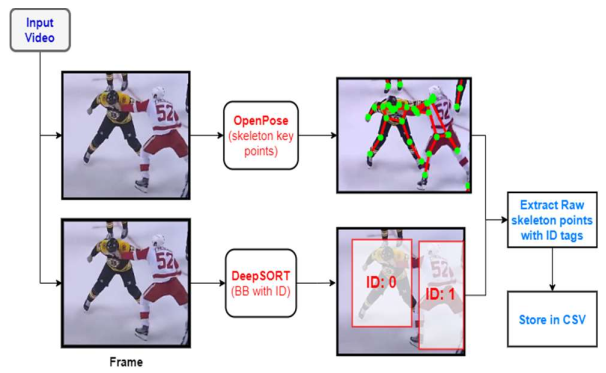
Deep Learning
Create custom Deep Neural Networks in Python tensorflow.
Publications
-
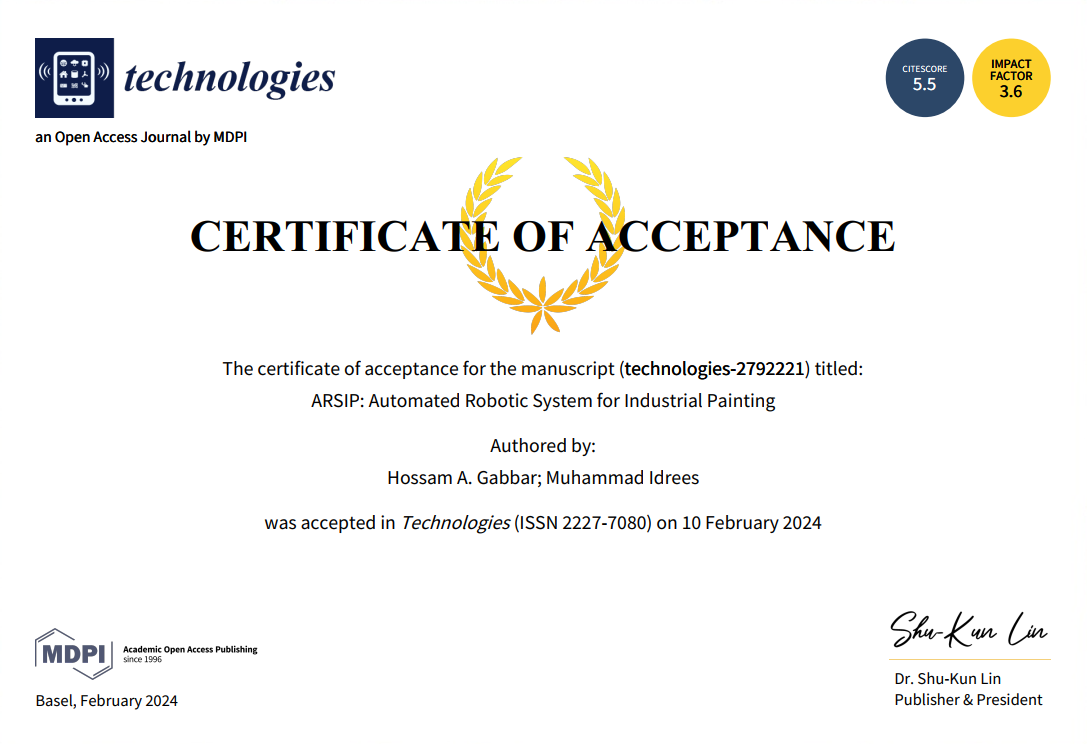
Gabbar, H.A.; Idrees, M. ARSIP: Automated Robotic System for Industrial Painting. Technologies 2024, 12, 27. https://doi.org/10.3390/technologies12020027
-
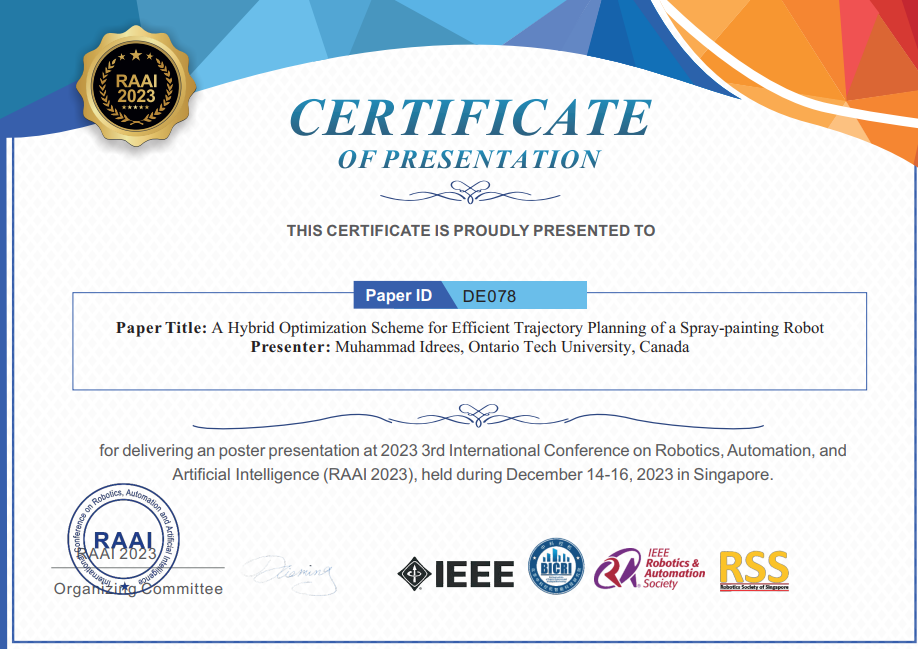
Idrees, M.; Gabbar, H.A. A hybrid optimization scheme for efficient trajectory planning of a spray-painting robot. In Proceedings of the 3rd International Conference on Robotics, Automation, and Artificial Intelligence (RAAI), Singapore, 14–16 December 2023